Native GPU Processing
COLMAP-powered feature extraction, sparse reconstruction and dense stereo with compatibility handling for older NVIDIA hardware.
From RTK imagery to engineering-grade spatial outputs.
MaticTech Mapper is a professional desktop photogrammetry suite for transforming geotagged RTK drone imagery into orthomosaics, terrain models, point clouds, 3D models and GIS-ready deliverables—entirely on the operator's workstation.
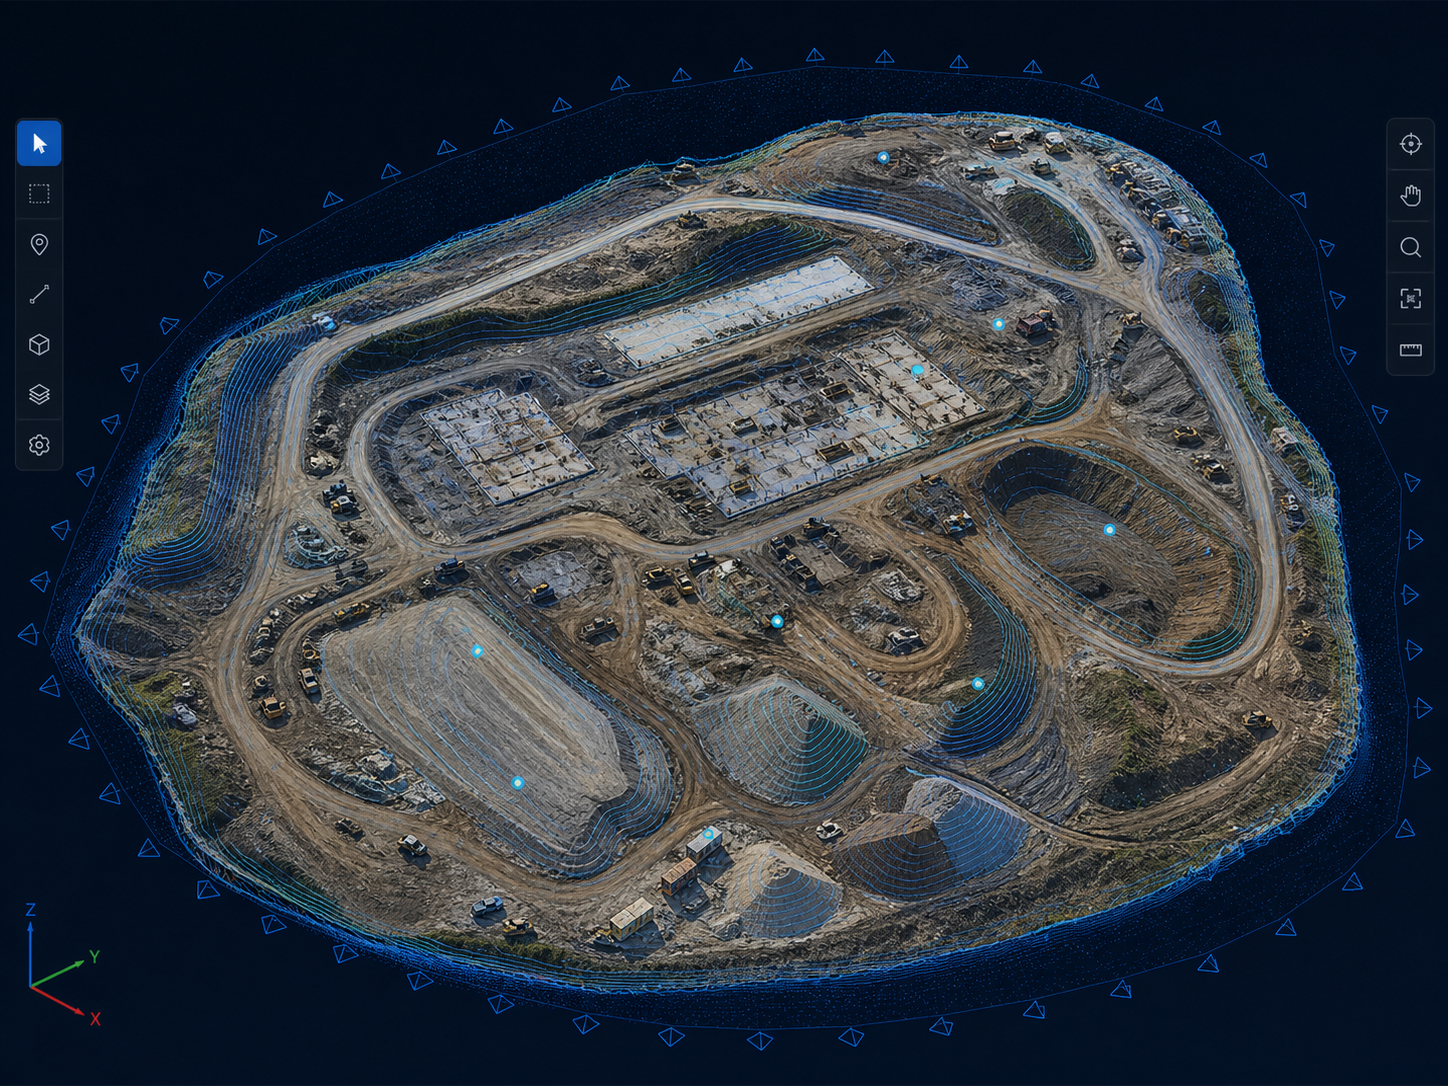
A single local workflow for reconstruction, georeferencing, analysis and export—built for survey teams that need control over their data and infrastructure.
COLMAP-powered feature extraction, sparse reconstruction and dense stereo with compatibility handling for older NVIDIA hardware.
High-precision geotags, PPK re-import, ground control points, coordinate systems and residual reporting.
Orthomosaics, DSM, DTM, contours and configurable ground sample distance for GIS workflows.
Local point-cloud and 3D visualization with LAS, LAZ, PLY, OBJ and Cesium 3D Tiles output.
Target-surface definition and volumetric comparison for construction progress and terrain planning.
Automated dataset checks, processing metrics, GCP residuals and printable technical reports.
Mapper 0.97 is available on request. Validation so far is a numerical comparison on one dataset; it is not an independent survey of accuracy.
Windows interface, project model, image import, processing engines and primary exports.
Distances, polygon areas, volumes, coverage and file outputs compared on the same 98-photo survey.
Orthomosaic footprint (86.55% of reference) and shared-base volume agreement (about 2.3%) are being improved.
Fresh end-to-end timing on identical hardware and validation on additional surveys and GCP workflows.
Same 98-photo SR9 survey, compared with the supplied PIX4D exports (19 October 2026, build 0.97.0-preview). The comparison covers stored output size, selected measurements and volumes, with the remaining differences listed.
| Parameter | PIX4D (supplied) | MaticTech Mapper |
|---|---|---|
| Photographs registered | 97 / 98 | 98 / 98 |
| Dense point-cloud points | 4,571,205 | 11,414,283 (2.50×) |
| Exported mesh triangles | 474,925 | 9,929,997 (20.91×) |
| Orthomosaic / DSM size | 12,350 × 12,525 px | 16,384 × 15,908 px |
| Output cell spacing | 1.3780 cm | 1.0468 cm |
| Reference footprint covered by valid orthomosaic | 100% (reference) | 86.55% |
| Recent 3D distance | 7.229 m | 7.209 m (0.277%) |
| Cable polyline | 28.301 m | 28.325 m (0.085%) |
| Roof edge | 25.421 m | 25.320 m (0.397%) |
| Roof polygon, 3D area | 345.7246 m² | 342.9044 m² (0.816%) |
| Long pile volume, shared boundary and base | 6.341 m³ | 6.191 m³ (2.37%) |
| Small object volume, shared boundary and base | 1.275 m³ | 1.245 m³ (2.33%) |
| Recorded processing time | 14 min 19 s (cloud backend log) | 2 h 44 min 57.7 s (one worker attempt, laptop) |
Mapper stores far more geometry, samples its rasters more finely, and agrees with PIX4D to under 1% on the selected distances and polygon areas.
Orthomosaic coverage is below the reference, volumes differ by about 2.3% on a shared base, and the recorded run time is longer. The two timings come from different hardware and logs, so no speed ratio is claimed.
More triangles or points do not by themselves mean higher accuracy, and finer cell spacing is not measured resolving power. These are comparisons against PIX4D, not surveyed ground-truth accuracy, and measurements used manually picked endpoints.
MaticTech Mapper is designed for in-house processing. Survey images and derived outputs remain on the operator's Windows workstation—without cloud processing fees, per-seat licensing or mandatory uploads.
Survey imagery moves through a controlled local pipeline—from RTK capture and dense reconstruction to measurable engineering outputs.
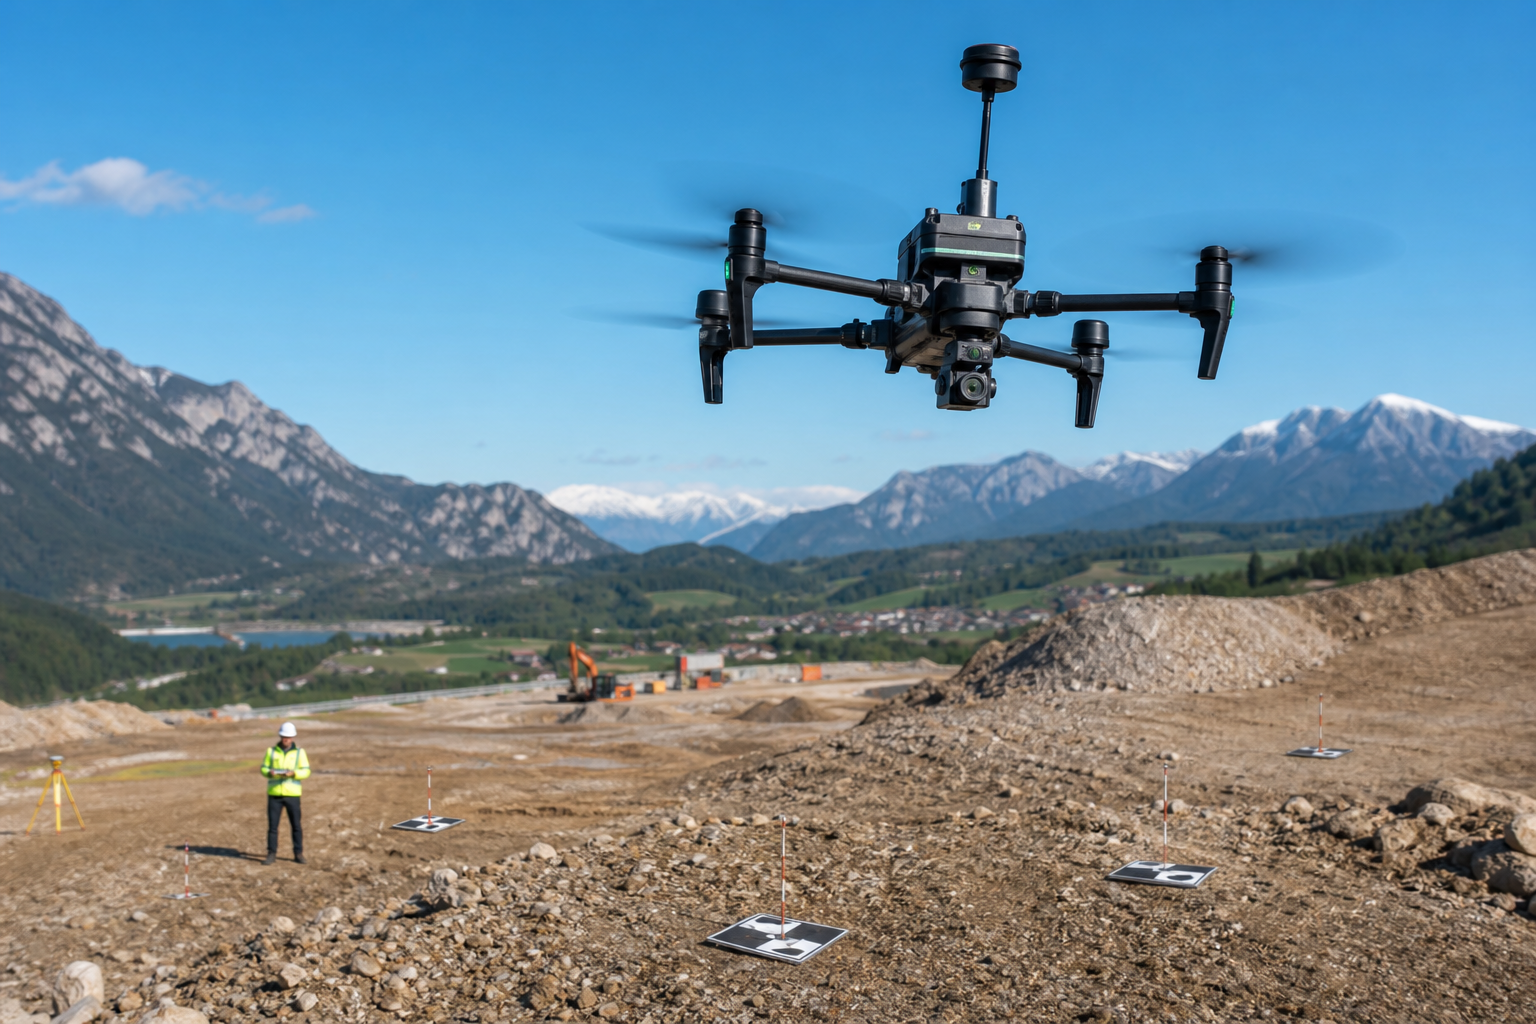
Geotagged aerial imagery, RTK precision, ground control and dataset validation before processing.
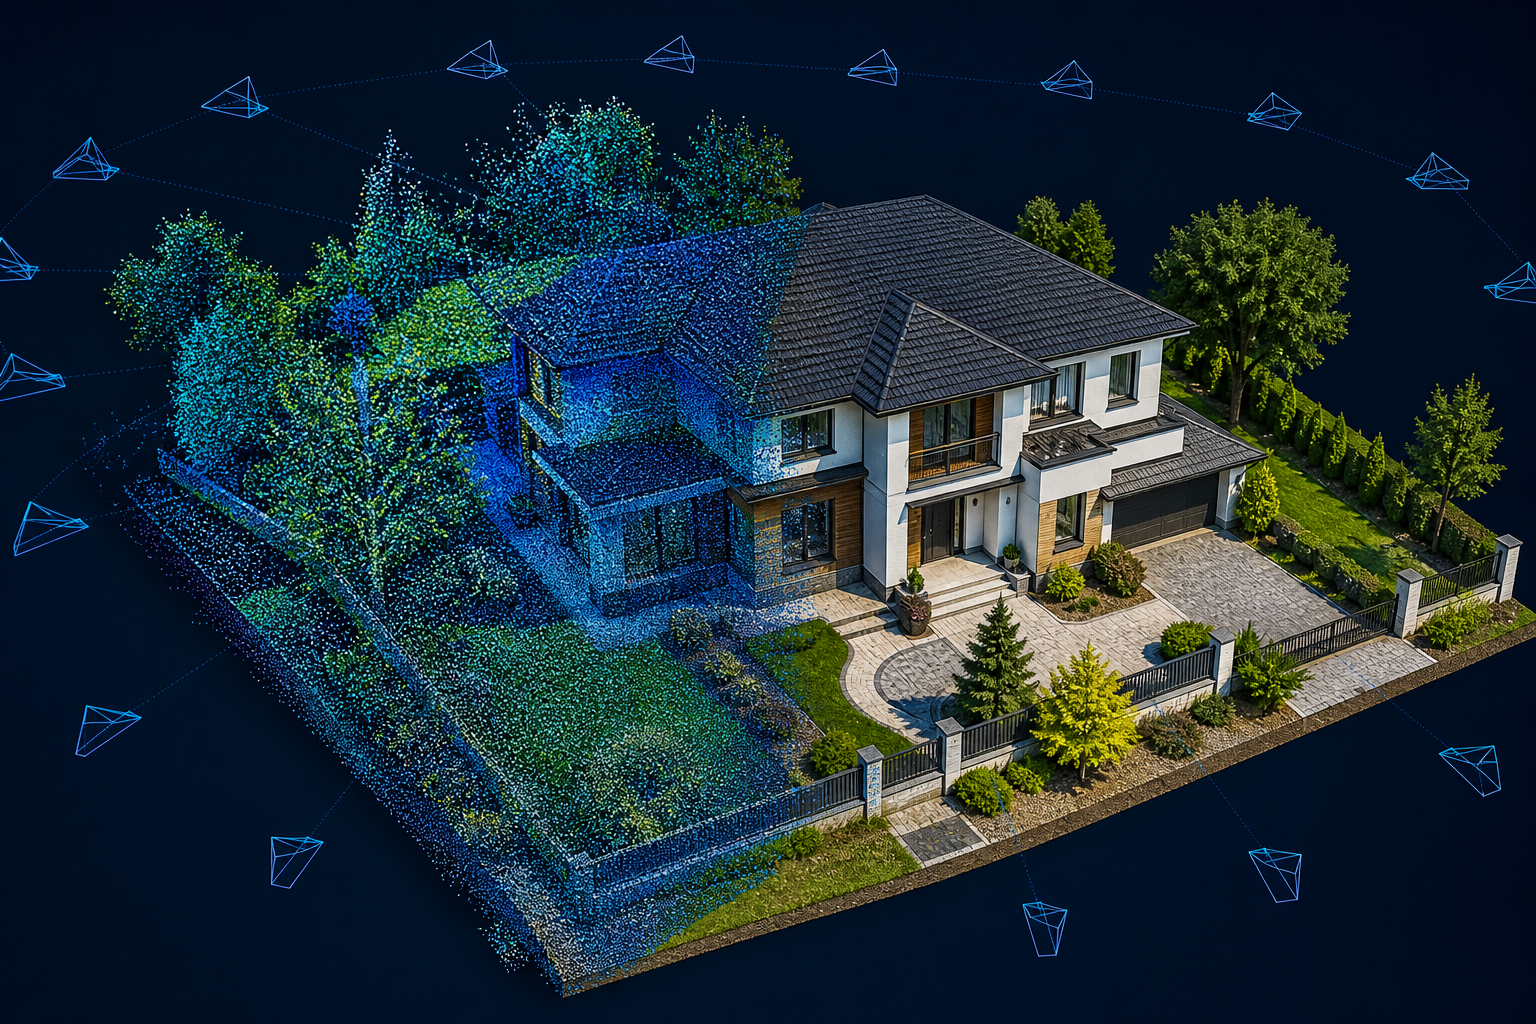
Dense point clouds and textured meshes reconstructed from overlapping drone photographs.
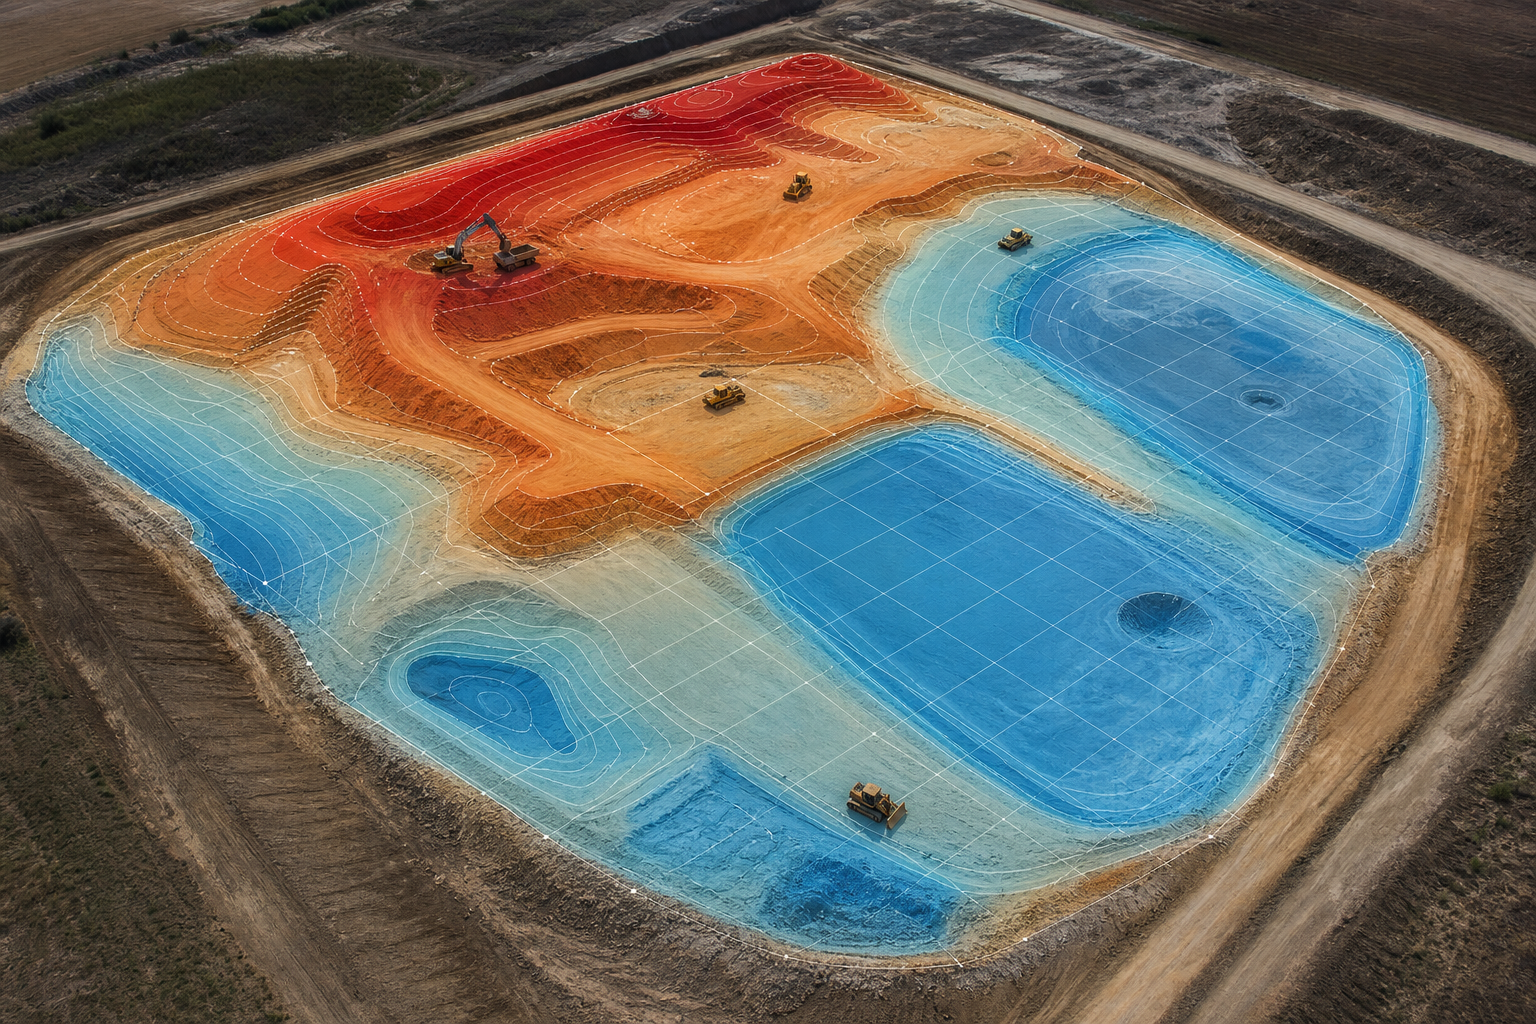
Existing terrain compared with a design surface to calculate and visualize earthwork volumes.
Research into parallel GPU kernels for selected photogrammetry workloads, throughput and memory locality. Not yet release ready.